
Introduction to Robotics
Prof. Dr. Abhinav Valada, Prof. Dr. Joschka Boedecker, Dr. Tim Welschehold
Co-Organizers:
Rohit Mohan, Shengchao Yan, Julius Körner
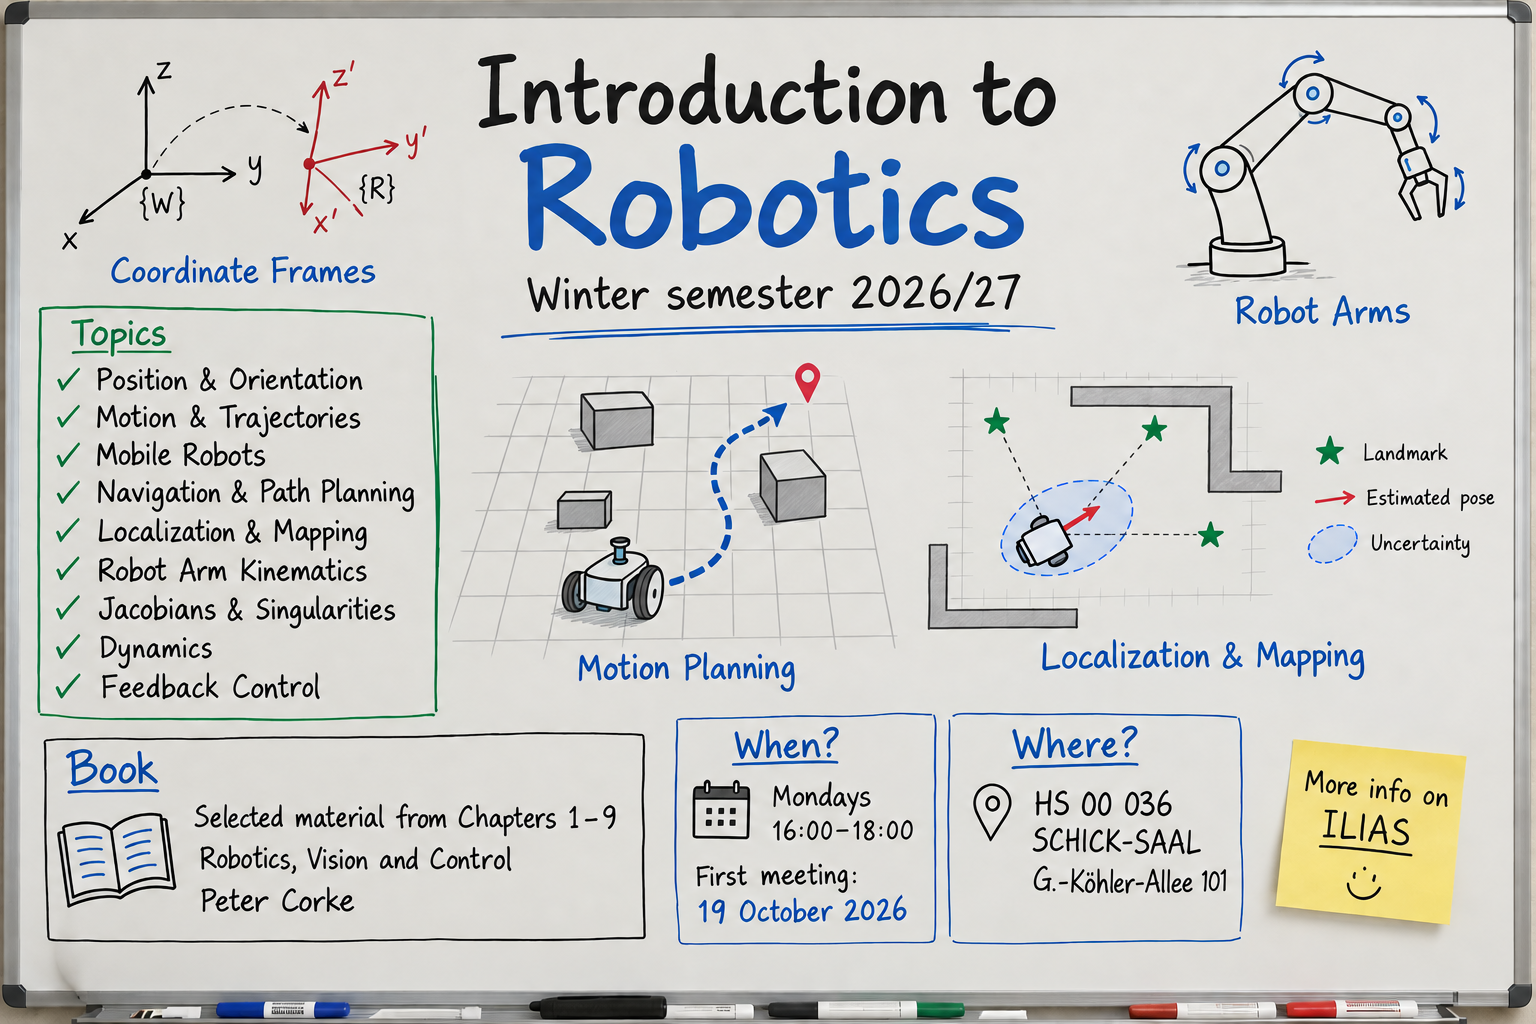
This course introduces the mathematical and computational foundations of robotics, covering both mobile robots and robot arms. Topics include coordinate frames and rigid transformations, robot motion and path planning, localization and mapping, arm kinematics and velocity relationships, and dynamics and feedback control.
The course follows selected material from Chapters 1–9 of Peter Corke's Robotics, Vision and Control, third edition.
Details
| Semester: | Winter semester 2026/27 |
| Course number: | 11LE13V-1423 |
| Time: | Monday, 16:00–18:00 First meeting on 19 October 2026. |
| Location: | HS 00 036, SCHICK-SAAL (G.-Köhler-Allee 101) |
| Language: | English |
| Learning Platform: | ILIAS |
| Exercise sessions: | Friday, 08:00–10:00 |
| Assessment: | Written Exam |
Course Overview
Teaching consists of weekly in-person lectures in English and exercise sessions. Lecture recordings, slides, exercises and solutions will be available on ILIAS. Further information about exercises will be announced.
Course Schedule
The following are the dates for the lectures:
No lectures on 21 December 2026, 28 December 2026 or 4 January 2027.
19.10.26 – Lecture 1: Introduction
26.10.26 – Lecture 2: Coordinate Frames and 2D Pose
02.11.26 – Lecture 3: Rotations and Pose in 3D
09.11.26 – Lecture 4: Motion and Trajectories
16.11.26 – Lecture 5: Inertial and Visual Sensing
23.11.26 – Lecture 6: Mobile Robot Motion Models
30.11.26 – Lecture 7: Navigation: Maps and Path Planning
07.12.26 – Lecture 8: Odometry and EKF Localization
14.12.26 – Lecture 9: SLAM and Loop Closure
11.01.27 – Lecture 10: Forward and Inverse Kinematics
18.01.27 – Lecture 11: Jacobians, Singularities and Forces
25.01.27 – Lecture 12: Manipulator Dynamics and Joint Control
01.02.27 – Lecture 13: Model-Based Robot Control
08.02.27 – Round-up / Exam Q&A
Questions?
If you have a question, please post it in the ILIAS forum (so everyone can benefit from the answer). Alternatively, you can also email ir-orga@cs.uni-freiburg.de